Springer Nature

Control Of Ships And Underwater Vehicles
Miglior prezzo disponibile
169,99$
Springer Nature · Spedizione gratuita
VISAPayPal
Prezzi aggiornati
Specifiche
MarcaSpringer Nature
CondizioneNuovo
Descrizione
Most ocean vessels are underactuated but control of their motion in the real ocean environment is essential. Starting with a review of the background on ocean-vessel dynamics and nonlinear control theory, the authorsâ systematic approach is based on various nontrivial coordinate transformations coupled with advanced nonlinear control design methods. This strategy is then used for the development and analysis of a number of ocean-vessel control systems with the aim of achieving advanced motion control tasks including stabilization, trajectory-tracking, path-tracking and path-following. Control of Ships and Underwater Vehicles offers the reader: - new results in the nonlinear control of underactuated ocean vessels; - efficient designs for the implementation of controllers on underactuated ocean vessels; - numerical simulations and real-time implementations of the control systems designed on a scale-model ship for each controller developed to illustrate their effectiveness and afford practical guidance.
Storico prezzi
Ricevi una notifica se il prezzo scende
Ti invieremo un'email quando il prezzo di questo prodotto diminuirà.
- Aggiornamenti dei prezzi in tempo reale
- Oltre 50 negozi monitorati
- Avvisi gratuiti di calo prezzo
- Solo negozi verificati
Avvisami quando il prezzo scende sotto: 169,99$
Prodotti simili
Una selezione di prodotti che potrebbero interessarti. Guarda tutti
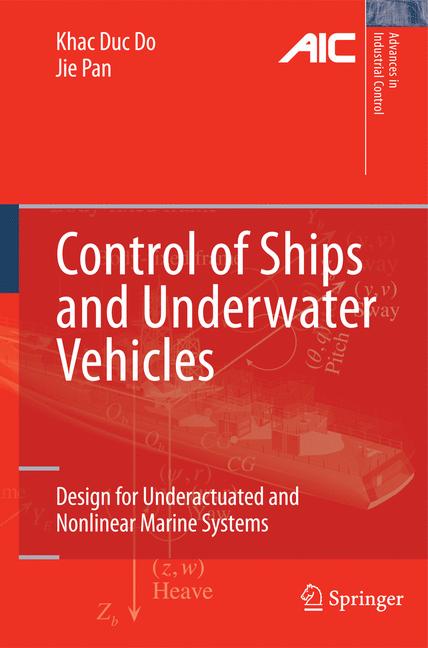 Control Of Ships And Underwater Vehicles
129,00$
 Dynamics Modeling And Maneuvering Of Autonomous Underwater Vehicles
159,00$
 Hotrc DS4A 4-Channel Remote Control Transmitter C-04A 4-12V 4CH Receiver, Suitable For Remote Control Of Vehicles And Ships
40,14$
 Development And Testing Of Navigation Algorithms For Autonomous Underwater Vehicles
84,99$
 Robust Model Predictive Control For Autonomous Underwater Vehicles
129,00$
 TD7 400W 24V 7Kg Thrust Underwater Thruster, Used For Underwater Machines And Unmanned Ships
454,60$
 Dynamics And Control Of Connected Vehicles
199,99$
 Nonlinear Control Of Vehicles And Robots
109,99$